- sales/support
Google Chat:---
- sales
+86-0755-88291180
- sales01
sales@spotpear.com
- sales02
dragon_manager@163.com
- support
tech-support@spotpear.com
- CEO-Complaints
zhoujie@spotpear.com
- Only Tech-Support
WhatsApp:13246739196
- Purchase/Shipping/Refund
WhatsApp:13424403025
- HOME
- >
- ARTICLES
- >
- Jetson Series
- >
- Jetson Kits
CF35-12 User Guide
Overview
Introduction
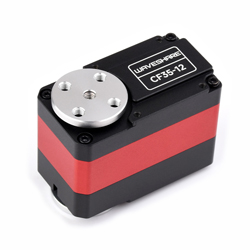
CF35-12 is a programmable dual-axis constant force serial bus servo with a stall torque of 35KG.CM. It has an all-aluminum alloy shell and an external high-strength aluminum alloy steering wheel. It uses a 360° high-precision magnetic encoder and can perform angle control within a 360° range. It can set any angle as the servo center position through program control; It can also be switched to continuous motor mode, multi-turn continuous rotation and other working modes, with built-in acceleration start-stop function, making the action smoother. Each bus servo has two interfaces, allowing the servos to be connected in series. Theoretically, up to 253 servos can be controlled simultaneously, and each servo can obtain its current angle, load, voltage, mode, and other information. It can be used to build multi-axis small-volume steering robot projects such as quadruped, hexapod, and robotic arm, and easily handle large objects.
Features
- 360° magnetic encoder, high precision, angle control accuracy up to 360°/4096
- Any angle can be set to the servo center position for easy assembly
- Acceleration start-stop function, smoother motion effects
- Compact structure design, more beautiful product appearance
- Wide voltage input of 9-12.6V, can be directly powered by 2S or 3S lithium batteries
- Stall torque up to 35kg.cm@12V
- Multiple working modes can be set:
- Angle control mode
- Motor constant speed control mode
- Motor constant current control mode
- Can be used in series to control up to 253 bus servos at the same time (provided that the power supply is sufficient) and obtain feedback information for each bus servo
Specifications
| CF35-12 | |||
|---|---|---|---|
| Typical operating voltage | 12V | Operating Voltage | 9~12.6V |
| No-load current | 150mA | No-load speed | 0.222sec/60° (45RPM) |
| Static current | 26mA | Locked-rotor current | 2.8A |
| Torque | 35kg.cm | Rated load | 8.7kg.cm |
| Rated current | 800mA | Kt constant | 12.5kg.cm/A |
| Output shaft | 25T/OD5.9mm | Reduction ratio | 1/345 |
| Total weight | 70.5±1g | Gear backlash | ≤0.5° |
| Baud rate | 38400bps~1Mbps (default 1Mbps) | ID range | 0~253 |
Servo Interface and Wiring Description
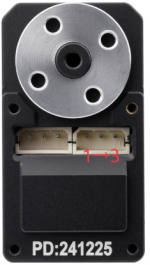
- Interface type: 5264-3P
| Interface number | Name | Cable color | Type |
|---|---|---|---|
| 1 | Signal/TTL | White | Signal cable |
| 2 | VCC | Red | Power Positive |
| 3 | GND | Black | Power Negative |
Product Usage
Hardware Connection
We currently have four driver boards that can drive and control the servo, and you can choose according to your needs:
If you wish to use bus servos in your own project, you can refer to Schematic diagram of bus servo control circuit.
Resources
3D Model
Demo
Support
Monday-Friday (9:30-6:30) Saturday (9:30-5:30)
Mobile: +86 13434470212
Email: services01@spotpear.com