




- sales/support
Google Chat:---
- sales
+86-0755-88291180
- sales01
sales@spotpear.com
- sales02
dragon_manager@163.com
- support
tech-support@spotpear.com
- CEO-Complaints
zhoujie@spotpear.com
- Only Tech-Support
WhatsApp:13246739196
- Purchase/Shipping/Refund
WhatsApp:13424403025
- HOME
- >
- ARTICLES
- >
- Common Moudle
- >
- ESP
ESP32-MINI-Drone-A User Guide
I. Project Overview
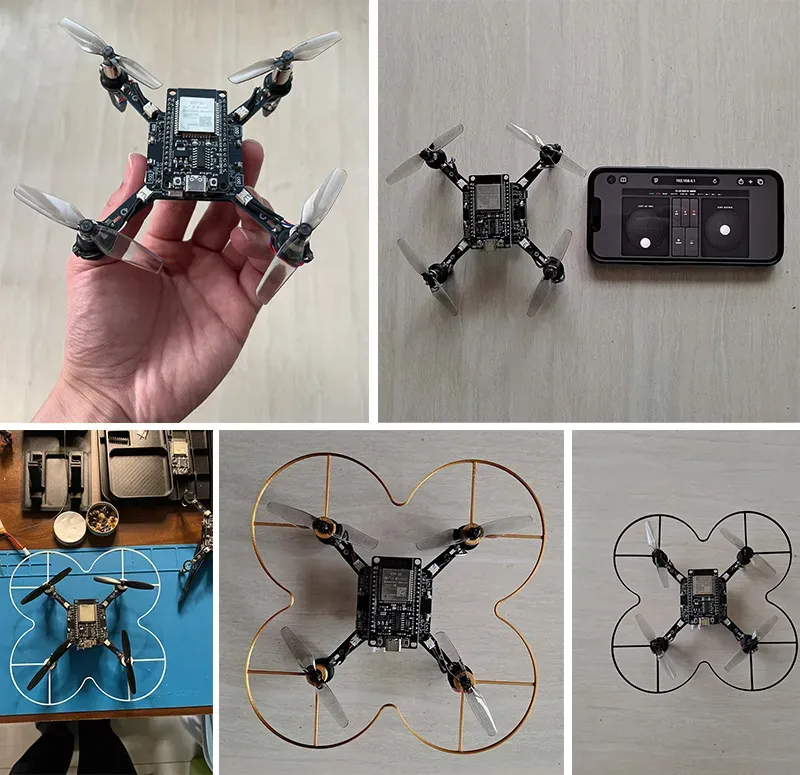
Based on an ESP32 development board, this mini quadcopter uses the ESP32 board as the main controller, employs only a single gyroscope sensor, and comes with a built-in web-based remote controller. Its minimalist hardware and software design makes it easy to get started with—only simple soldering and firmware flashing are required, and it can take off without complex configuration.
The aircraft comes with a built-in web-based remote controller, so you can control it simply by accessing it from your phone—no need to install an additional app or use a physical remote. Of course, it also supports app-based and physical remote control.
Simple yet sophisticated—every detail has been carefully refined.
Specifications
- Main controller: ESP32
- Wheelbase: approx. 118 mm
- Weight: approx. 80 g (including standard battery)
Quick Start
III. Project Replication
Just follow the steps and it will definitely fly! Replication takes only three steps:
- Hardware Assembly
- Software Flashing
- Simple Debugging
Step 1: Hardware Assembly
1. Download the [Bill of Materials spreadsheet] from the attachments on this page, prepare the materials according to the BOM, and fabricate the PCB.
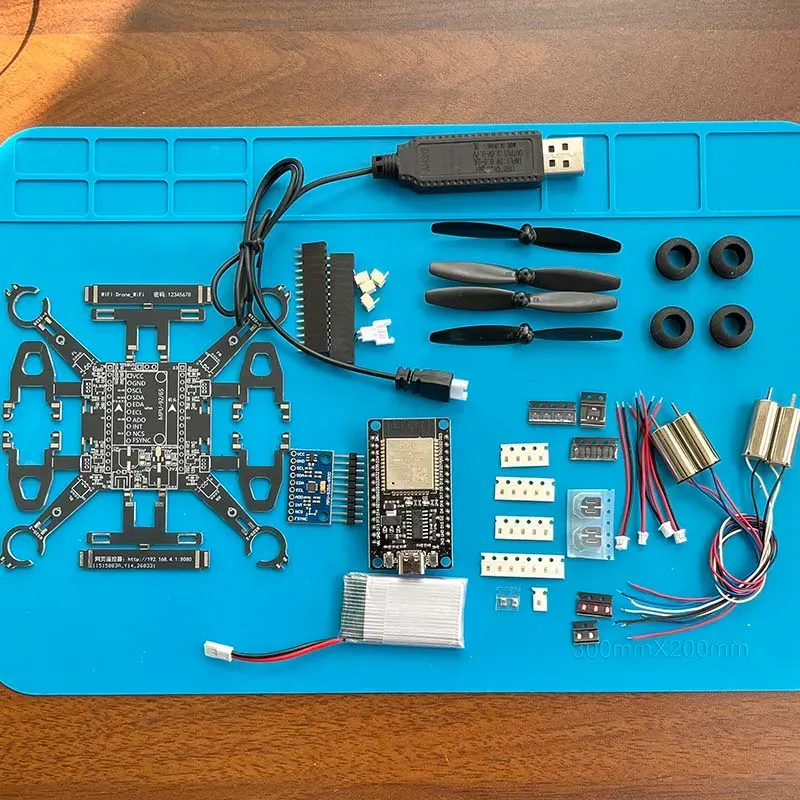
The PCB thickness should preferably be 1.6 mm, as the slot dimensions for the base and bracket are designed for 1.6 mm.
Try to buy higher-quality main components; accessory quality varies widely and will directly affect the build results.
The development board is an ESP32 30-pin. Those who are new to development boards should note that ESP32 boards come in many versions, such as C3/S3/CAM, etc. What you need is the version with no suffix—ESP32—with 30 pins.
The battery is a 1S RC model/drone battery with a voltage of 3.7–4.2 V. Do not buy an ordinary lithium battery; one with a high discharge rate is required.
The complete bill of materials is provided in the [BOM spreadsheet] in the attachment at the bottom of this page, including model numbers, packages, and detailed descriptions. The BOM only covers circuit components, and placing an order directly from it may result in mismatches; it is for reference only.
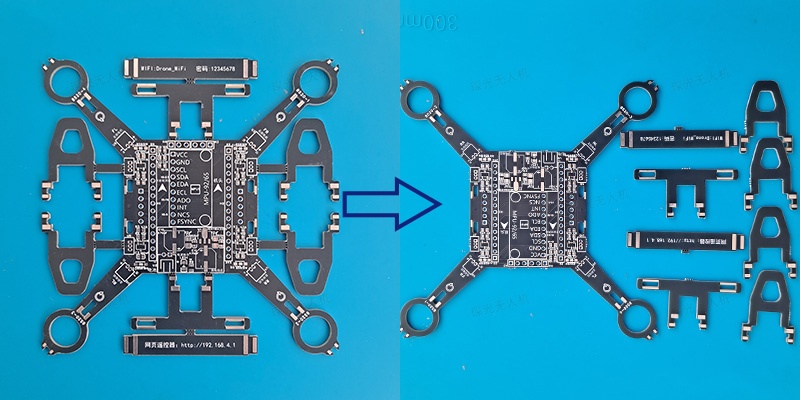
2、Separating the PCB. The front, back, left, and right sections are the motor mounts and bracket parts, while the middle section is the main control board. The new PCB has added silkscreen markings for the corresponding divisions.。
Before assembly, separate the main control board section from the motor mounts and hanger. You can use tools to help with the separation—flush cutters make it easy to cut them apart.。
3、Soldering the components. If you are soldering with an electric soldering iron, it is recommended to solder the smallest SMD components first, then the larger SMD components, and finally the through-hole components, pin headers, sockets, etc.
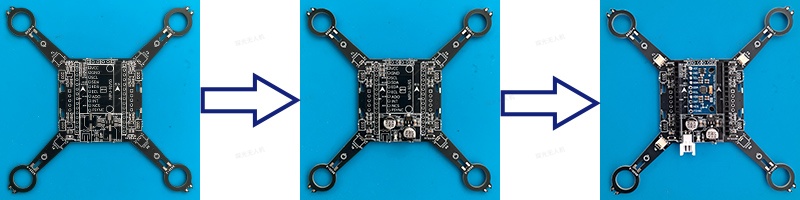
There are two relatively large 470 µF capacitors on the main control board to relieve pressure on the battery. If you buy a battery of good quality, these two capacitors can be omitted. The LED is also a non-essential component and can be left uninstalled.
The gyroscope module can be soldered flush against the main control board without pin headers, which reduces installation deviation. If you are not skilled at soldering, it is recommended to use pin headers for soldering.
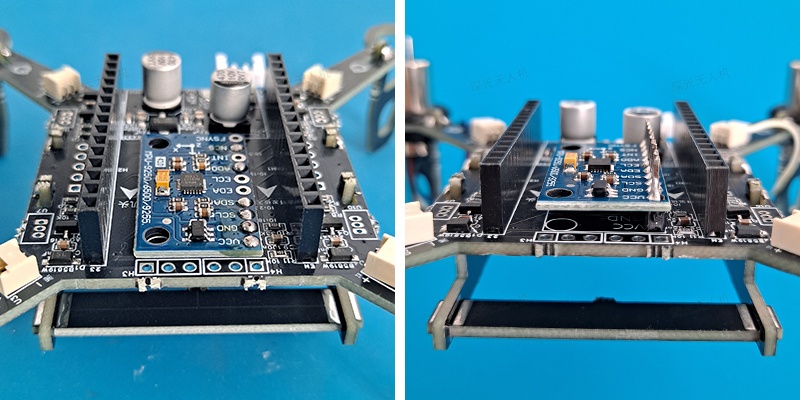
The gyroscope module can be soldered with only the VCC / GND / SCL / SDA / AD0 / NCS pins, or all pins can be soldered.
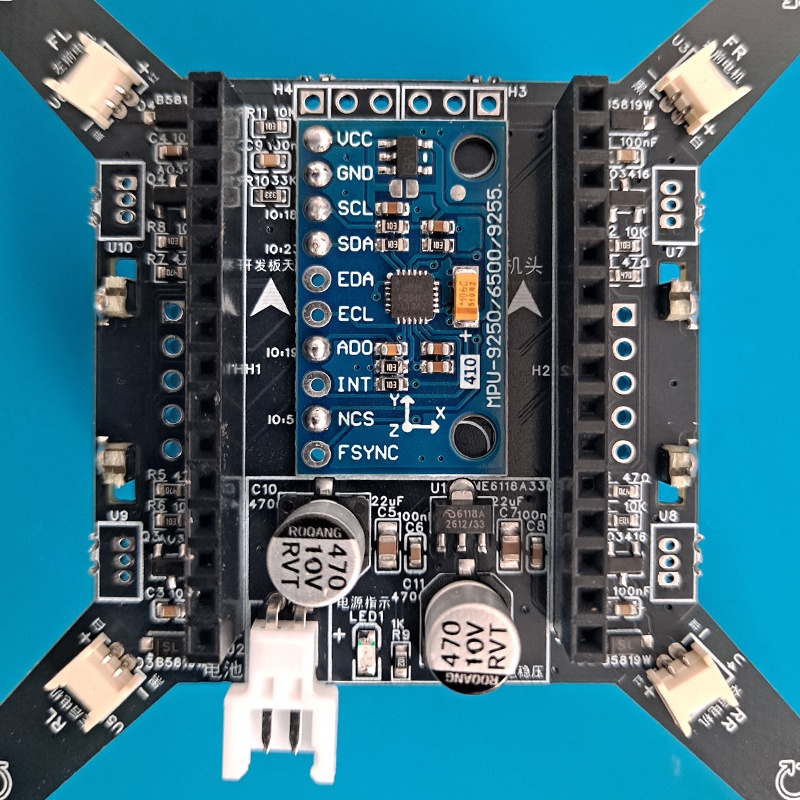
After soldering is complete, it is recommended to use a multimeter to do a simple test of the circuit for cold solder joints or short circuits, and confirm there are no problems before applying power. Even a welder with 30 years of experience using an electric soldering iron cannot guarantee success the first time when soldering 0603 components.
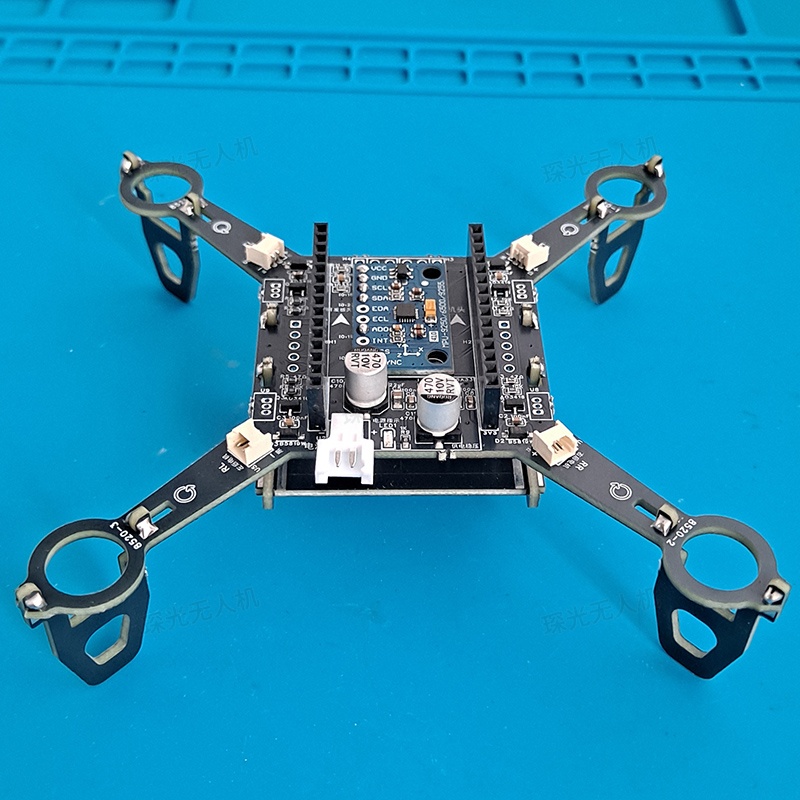
4、Soldering the motor mounts and brackets. The motor mounts can effectively protect the drone when it loses control, and they also serve as support for the entire aircraft. Installation is recommended.。
The bracket can be used to hold the battery. The bracket is 12 mm high, so batteries with a thickness of less than 12 mm will fit. You can also use a rubber band to secure the battery.。
There are soldering pads near the bracket; reinforce them with solder.。
Here's what it looks like after soldering.
The back side.
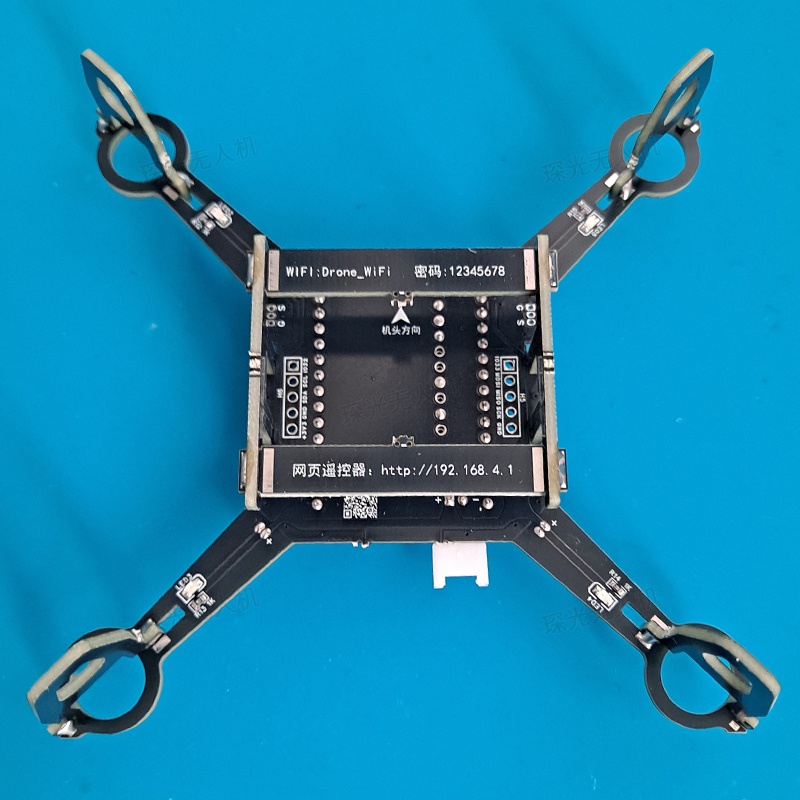
5、Installing the motors. The motor rotation direction must follow the specified direction; the PCB has silkscreen markings indicating the corresponding rotation direction, and the two diagonal motors must rotate in the same direction.
It is recommended to use two motors with black-and-white wires and two with red-and-blue wires, as color-coded installation is more intuitive. The PCB silkscreen indicates the wire colors and polarity. Alternatively, four motors with the same wire color can be used.。
The motors are secured to the bracket with rubber rings, or fixed directly with hot glue.
Reference for motor rotation direction.:
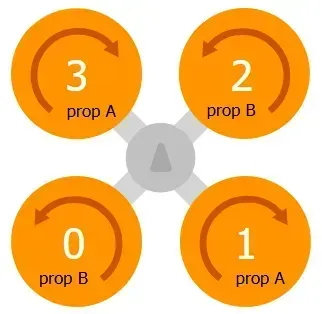
6、Installing the propellers. The propellers must also be installed in the specified direction!
When the motor rotates in the marked direction, the higher side of the propeller should face forward and blow air downward. The diagonal propellers must also face the same direction. You can refer to the installation direction shown in the figure below.
The most reliable approach is, after debugging is complete, to arm the motors and confirm that all four propellers blow air downward.
The mechanical strength of the motors and propellers is limited, so do not use excessive force during installation—just install them snugly.
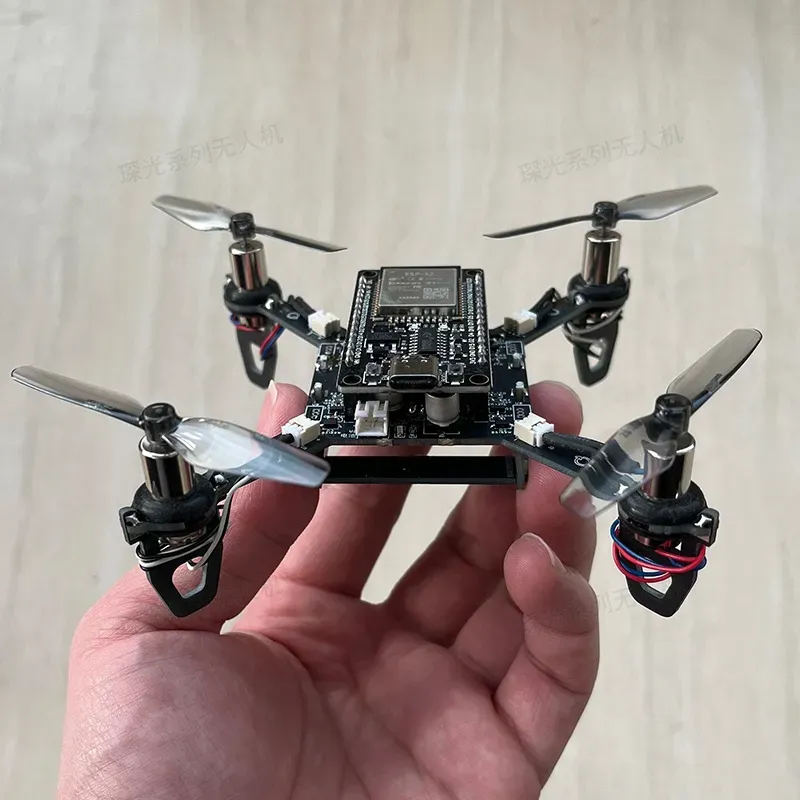
The propeller guards are 3D-printed parts. The model files are in the attachments and can be downloaded and printed. Installing them makes it safer, so installation is recommended.
Step 2: Software Flashing
1. Download the compiled BIN firmware file.。
MINI firmware 20261021.bin
2、Connect the ESP32 development board to the computer using a USB data cable. (If the computer does not automatically install the serial port driver, you need to install it manually; you can check this in the computer's Device Manager.)
3、Use the official Espressif tool to flash the firmware. Download address for the flashing tool.:https://docs.espressif.com/projects/esp-test-tools/zh_CN/latest/esp32/production_stage/tools/flash_download_tool.html
Flashing settings:
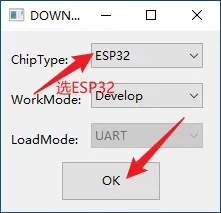
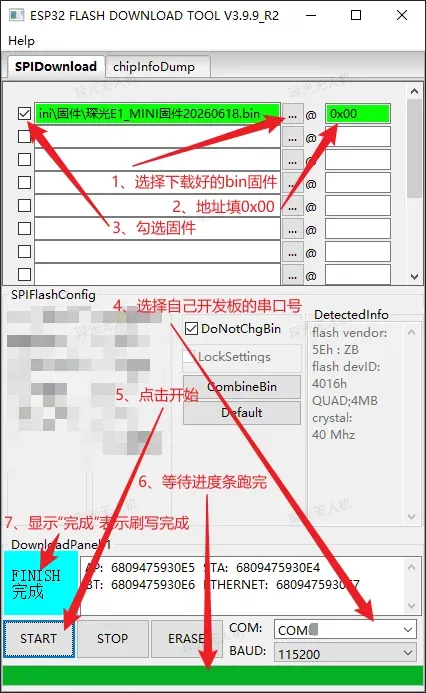
If you don't know which serial port to use, plug and unplug the development board and see which port number changes—select that one.
Step 3: Debugging and Takeoff
1、Connect the battery to the drone, and connect your phone to the drone's Wi-Fi: Drone_WIFI, password: 12345678.
Some phones have an automatic network optimization feature that automatically switches between Wi-Fi and mobile data, so it needs to be disabled; or a more direct approach: turn off mobile data on your phone.
2、Open your phone's browser and enter the address.:http://192.168.4.1 After confirming, open the remote controller interface.
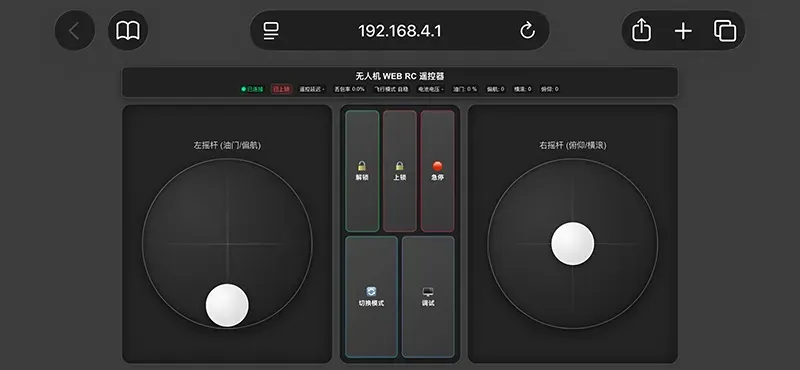
3、Debugging. In the web-based remote controller, click the "Debug" button, and you can enter debugging commands in the pop-up debug interface. It is recommended to remove the propellers before debugging.
- Calibrate the IMU (required). Enter the debug command "ca" and position the drone according to the prompts. Refer to this prompt:
1/6 Place horizontally: nose facing forward (normal flight direction), bottom facing down, placed horizontally on a flat surface, ensuring it is completely level with no tilt. Keep it still; calibration will begin after 8 seconds.
Horizontal calibration complete. Please continue.
2/6 Nose up: Keep the nose facing forward, point the nose toward the sky, and let the tail face down and touch the supporting surface, perpendicular to the ground. Keep it still; calibration will begin after 8 seconds.
Nose-up calibration complete. Please continue.
3/6 Nose down: Keep the nose facing forward, point the nose toward the ground and touch the supporting surface, with the tail facing up and perpendicular to the ground. Keep it still; calibration will begin after 8 seconds.
Nose-down calibration complete. Please continue.
4/6 Right side down: Keep the nose facing forward, position the right side of the aircraft downward and touching the supporting surface, with the left arm facing up and perpendicular to the ground. Keep it still; calibration will begin after 8 seconds.
Right-side-down calibration complete. Please continue.
5/6 Left side down: Keep the nose facing forward, position the left side of the aircraft downward and touching the supporting surface, with the right arm facing up and perpendicular to the ground. Keep it still; calibration will begin after 8 seconds.
Left-side-down calibration complete. Please continue.
6/6 Upside down: Keep the nose facing forward, completely flip the aircraft so the top faces down and the bottom faces up, with the whole unit in a horizontal upside-down position. Keep it still; calibration will begin after 8 seconds.
✓ All calibration complete! Return the aircraft to an upright position and run the ps command to view the calibration results.
After calibration is complete, return the drone to an upright position (top facing up) and enter the command "ps" to view the calibration results. You will see something like:
roll: 0.521120 pitch: -0.062948 yaw: 82.711197
If roll/pitch are close to 0, calibration is successful. The normal range is within 0.5, the acceptable range is within 2, and if it exceeds 5, recalibration is required.
yaw can be ignored; the MPU6500 has no magnetometer, so the yaw axis is a virtually calculated value.
IMU calibration only needs to be done once. After that, as long as there is no major deviation, hardware replacement, or firmware rewrite, it does not need to be done again.
- Test the motors (optional). First remove the propellers from the motors! To avoid injury!
Enter the commands "mfl/mfr/mrl/mrr" respectively, corresponding to the front-left, front-right, rear-left, and rear-right motors, and observe whether the four motors rotate normally.
If your phone screen is too small and debugging is inconvenient, you can also use Arduino or GQC for debugging. Refer to the content in the "In-Depth Study" section.
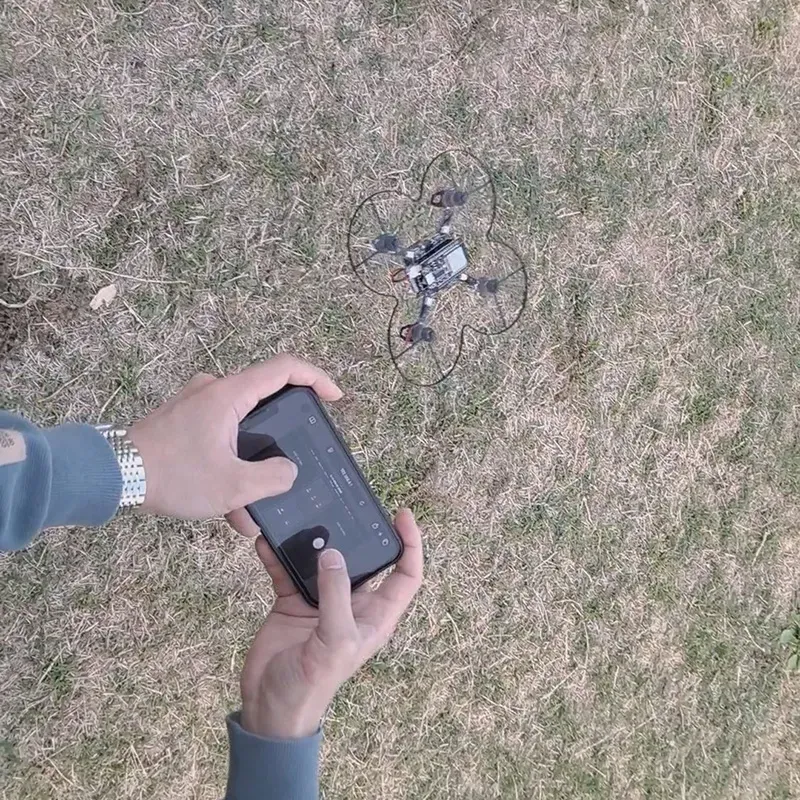
4. Takeoff. Click the arm button, push the throttle, and take off!
IV. In-Depth Study
If you are only doing a simple replication, the following sections can be ignored.
This project is released under the CC BY-NC-SA open-source license; commercial use without authorization is prohibited.
Related Resources
Hardware and software documentation, FAQs:http://docs.cherglowtech.com/
Companion ground station (under development):https://gc.cherglowtech.com/
Open-source flight controller source code:https://github.com/songge8/CF-Drone
The flight control software is developed using Arduino and can be developed and compiled with Arduino. The console built into the Arduino IDE can also be used for aircraft debugging. The aircraft can also use flight control programs written in any development language, as long as they are compatible with the ESP32 and MPU6500 hardware.
Design drawings and schematics.:https://pro.lceda.cn/editor#id=05f7ecdc689445648d7267c7c936f432
Reserved interfaces.
The main board has four reserved data interfaces, by default I2C, SPI, remote control receiver, and spare. They can be used to connect external devices such as sensors and remote controls, or to supply power to external devices.
The Chenguang sensor expansion module is perfectly compatible with the reserved interfaces. It includes a barometer, magnetometer, laser rangefinder, and optical flow sensor, enabling altitude hold or position hold hovering. The flight controller automatically detects whether the corresponding sensors are present and automatically enables altitude hold and position hold flight modes.
A brushless ESC interface is reserved, allowing brushless motors to be installed without modifying the original hardware.
Supports physical remote control, mobile app control, and the MAVLink protocol.
Physical remote control.
The remote control receiver interface reserved on the main board supports the mainstream CRSF (ELRS)/SBUS remote control protocols. For SBUS, software inversion has been implemented, so no hardware inverter is needed; CRSF (ELRS) supports one-way control input—simply connect the receiver's GND, 5V, and TX → the drone's G, V, and IO4.
How to Set Up a Physical Remote Control:
- Ensure the remote control and receiver are properly connected and the receiver protocol is set correctly.
- Connect the drone and the receiver.
- Set the receiver interface protocol and the corresponding baud rate via console commands: RC_PROTOCOL, remote control protocol, 0=SBUS, 1=CRSF(ELRS) (default); RC_BAUD, remote control serial port baud rate (bps), SBUS=100000, CRSF=420000 (default); example command format: P RC_PROTOCOL 1;
- Calibrate the remote control; in the console, use the CR command and follow the prompts.
- Move the left stick fully to the bottom-right to arm, and fully to the bottom-left to disarm.
QGC mobile app.
The app is available on the official QGC website.https://qgroundcontrol.com/ Download it. In addition to being used to control the aircraft, the APP's Analyze Tools - Mavlink Console can also be used for flight controller debugging.
MAVLINK
The firmware supports the MAVLink protocol.
Wireless mode.
The web remote controller/app remote control supports AP mode (default) and STA mode.
Video transmission.
You can refer to the implementation solutions shared by users in the comment section or in the comments of the video tutorials.
V. Changelog
V1.3
- The reserved data interfaces have been expanded to 4 groups, defaulting to I2C, SPI, ELRS/CRSF/SBUS, and spare.
- Recalculated dimensions and position data for higher mechanical precision.
- Rewired, preserving a complete ground plane with zoning.
FAQ
Tips for connecting several polarized components.
Component positions and orientations may differ between hardware versions; refer to the actual PCB silkscreen.
- For diodes, the vertical line on the component marks the negative terminal, corresponding to the vertical line on the PCB silkscreen.
- For LEDs, the green lead on the front of the component / the direction of the arrow on the back marks the negative terminal, corresponding to the pointed end of the PCB silkscreen.
- For electrolytic capacitors, the black marking on the component indicates the negative terminal; simply match the shape on the bottom of the component to the corresponding shape on the PCB silkscreen.
- For motor wire connectors, it is sufficient that one wire color on the motor matches one wire color on the plug—red to red, black to black. (This is not an industry standard; it applies only to the components in the material kit.)
Component soldering positions.
Any of the following methods can be used.
- Each component's reference designator and value are printed on the PCB. Locate the corresponding position using the reference designator or value. (Recommended)
- Interactive online component location reference diagram. https://pcbbom.cherglowtech.com/pcb/E1MiniV1.3Y
- PCB design drawings.
Unable to download/stuck at sync when flashing firmware
The flashing process takes about several tens of seconds. If an error occurs, or if it finishes too quickly or takes too long to complete, troubleshoot item by item according to the following:
Plug the data cable directly into the computer's USB port; do not use a USB hub or docking station.
It is recommended to use an Android phone data cable. Some cables only support charging and have no data transfer function.
Check whether the serial port driver is installed successfully. After the driver is installed, you should see something like "USB-SERIAL CH340 (COMX)" under the "Ports" section in the computer's Device Manager.
If the port is not visible, install the CH340 or the corresponding serial port chip driver and try again.
Official download address for the CH340 driverhttps://www.wch.cn/downloads/CH341SER_MAC_ZIP.htmlDo not open Arduino and the Espressif flashing tool at the same time, as the serial port will be occupied.
Confirm that the correct board model is selected in the flashing tool, and verify that the board model displayed in the title bar of the flashing tool is ESP32.
The development board may not have entered download mode. Perform the following steps:
Plug the development board into USB, open the ESP32 flashing software, and select the board's serial port. Press and hold the BOOT button on the development board without releasing it, click START in the flashing software, and once you see it start connecting, release the BOOT button; the development board will then enter download mode.Confirm that the firmware was downloaded from official channels (project documentation, QQ group files, etc.) and matches the corresponding model. Third-party firmware and MINI/Nano firmware are not interchangeable.
The flashing address is "0x00", where "0" is the Arabic numeral and "x" is the English letter; no other characters may be used in place of them.
Confirm that the correct development board serial port number is selected. The development board serial port number must be selected from the list and cannot be entered manually.
The drone's Wi-Fi cannot be found / cannot be connected.
Normally, the drone's Wi-Fi signal will appear within several tens of seconds after power-on, and there will be some delay when the phone refreshes the signal list. If it does not appear for a long time, please troubleshoot according to the following steps.
Do not connect the development board to the drone; connect it to the USB data cable alone to avoid a short circuit that could prevent the development board from starting normally and affect troubleshooting.
Confirm that the firmware was downloaded from official channels (project documentation, QQ group files, etc.) and matches the corresponding model. Third-party firmware may not have Wi-Fi functionality, and MINI/Nano firmware is not interchangeable.
Confirm that the firmware has been written correctly. It is recommended to use the latest firmware. Sometimes poor contact of the computer port/data cable causes write errors, which can lead to Wi-Fi connection failure or password errors. You can try changing the computer port/data cable, erasing the development board's storage, and then re-flashing the firmware.
Correct default Wi-Fi name: Drone_WiFi, password: 12345678 (printed on the body).
If you have changed the account and password, use the modified account and password to connect. If you forget the password, you can erase the development board's storage and re-flash the firmware to reset it.
A Wi-Fi signal starting with ESP_XXXXXX is the development board's factory default signal, which means the firmware was not flashed successfully. Flash the firmware and try again.Low battery power may be unable to drive the Wi-Fi.
After the firmware is written correctly, power the development board back on, and the blue indicator light on the development board will flash once. If the blue indicator light does not light up or stays on continuously, it means the firmware was not written successfully or the program is not running properly. Troubleshoot according to the following methods.
Close the flashing tool/Arduino to prevent the serial port from being occupied, and open the web console.https://tools.cherglowtech.com/espwebconsole/ ,Connect to the development board's serial port and check whether there are any error messages.。
E (30) qio_mode: Failed to set QIE bit, not enabling QIO mode
assert failed: __esp_system_init_fn_init_flash startup_funcs.c:118 (flash_ret == ESP_OK)
Backtrace: 0x4008c03c:0x3ffe3a70 0x4008c001:0x3ffe3a90 0x40092905:0x3ffe3ab0 0x400fa6df:0x3ffe3bf0 0x400fbc26:0x3ffe3c10 0x400fbc5e:0x3ffe3c30 0x40081dd6:0x3ffe3c60 0x40079912:0x3ffe3c90 |<-CORRUPTED
ELF file SHA256: 242e6edee
E (408) esp_core_dump_flash: Core dump flash config is corrupted! CRC=0x7bd5c66f instead of 0x0
E (416) esp_core_dump_elf: Elf write init failed!
E (421) esp_core_dump_common: Core dump write failed with error=-1
Rebooting...
If the console repeatedly displays the above information, please take a screenshot and contact customer service; the development board needs to be returned to the factory for inspection.
The web remote control won't open.
Before connecting, first confirm that the drone firmware has been flashed successfully.
Confirm that the firmware was downloaded from official channels (project documentation, QQ group files, etc.).
Confirm that the phone is connected to the drone's Wi-Fi and that mobile data has been turned off.
Web remote control address http://192.168.4.1
Or http://192.168.4.1:8080 (For old firmware versions only; deprecated)Some browsers distinguish the address bar from the search bar; the address must be entered in the address bar.
Do not use the built-in browsers in WeChat/QQ, as these browsers generally have special restrictions.
"IMU fault" is displayed.
In this project, the terms IMU, gyroscope module, attitude sensor, and accelerometer all actually refer to the IMU (MPU6500 module).
This prompt indicates that the IMU (MPU6500 module) has a cold solder joint, short circuit, or is not working properly.
Old firmware versions (before 202609xx) do not support expansion modules. If an expansion module is installed with an old firmware version, it will directly report an IMU fault. For using expansion modules, it is recommended to use the latest firmware version.
"Uncalibrated accelerometer" is prompted when unlocking.
Use the "ca" command in the web remote control debugging interface or console, calibrate the IMU according to the prompts, and then operate again.
Normal range for IMU calibration data
Use the `ps` command to check the attitude data after calibration. If roll/pitch are close to 0, the calibration is successful. The normal range is within 0.5, the acceptable range is within 2, and if it exceeds 5, recalibration is required. yaw can be ignored; the MPU6500 has no magnetometer, so the yaw axis is a virtually calculated value.
The ROLL item shows 170+ after IMU calibration.
Place the body upright (development board facing up, bottom of the aircraft facing down), and then execute the PS command.
If the PS command still shows 170+ after placing the body upright, it indicates that the calibration is incorrect and the calibration operation needs to be performed again.
After IMU calibration, all data is NAN, or the PS command shows that the attitude data roll/pitch is all 0.000.
IMU (MPU6500 module) has cold solder joints, short circuits, or is not working properly. (New firmware will indicate an IMU fault.)
The IMU gets stuck at the first step for a long time during calibration, and the remote control may even disconnect.
IMU (MPU6500 module) has poor/cold solder joints, short circuits, or is not functioning properly. (New firmware will report an IMU fault.)
Does the IMU need to be calibrated every time it is powered on?
IMU calibration only needs to be done once. After that, it does not need to be redone unless there is a significant deviation, hardware replacement, or firmware rewrite.
Will the motor spin if no operation is performed after power-on?
Before the development board is flashed with firmware, some pins may have default pull-ups, which could start the motor. Do not power on before the firmware is flashed, or power on with the development board removed.
Under normal conditions, the motor will not spin if no operation is performed after power-on; it will only spin after arming/unlocking.
If the motor spins when no operation is performed after power-on, check the drive circuit for that motor channel. This situation may be caused by:
- A cold solder joint on the 10K resistor;
- The MOSFET is burnt out and stuck in a conducting state.
After arming (at idle speed), some motors spin while others do not.
You need to test and troubleshoot the motor and circuit issues. Follow the steps below:
Use the web remote/console debug commands mfl/mfr/mrl/mrr to test each motor in turn (remove the propellers before testing!). If a motor spins normally, it means both the motor and the drive circuit hardware are fine; if it does not spin, it means that motor or its drive circuit is not working properly, and further troubleshooting is needed.
To test a motor individually, remove the motor and connect its positive and negative terminals directly to an adjustable power supply. If the motor spins at 1V, the motor is normal. If an adjustable power supply is not available, a 1.5V dry cell or a drone battery can be used instead.
If the motor does not spin when tested with the debug command, but the motor itself tests normal when tested individually, then the motor drive circuit is likely the problem. Check whether the 47Ω and 10KΩ resistors and the MOSFETs in the motor drive circuit have cold solder joints, short circuits, or damage. (This is the most common case.)
The motor speeds are inconsistent when the throttle is increased.
When the throttle is increased, the motor speeds are adjusted in real time through flight controller attitude calculations and other algorithms, rather than being directly powered by the battery, so differing motor speeds are normal. However, if the aircraft rolls over or cannot take off, please troubleshoot according to the rollover issue.
If you need to test the motors, use the web remote/console debug commands mfl/mfr/mrl/mrr.
The drone rolls over or some motors stop spinning when taking off with throttle applied.
Necessary conditions for a normal takeoff:
- The battery's actual discharge rate must be 25C or above (the official kit battery has been tested and meets this requirement).
- The battery has sufficient charge.
- The motor rotation direction must be correct.
- The propeller orientation must be installed correctly.
- The IMU calibration is correct, and the calibration error is within the acceptable range.
- There are no cold solder joints or short circuits in the circuit.
After troubleshooting the above issues, the drone should be able to take off normally.
How do I operate the web remote control?
The web remote control layout is Mode 2 (American hand). You can find some FPV drone control tutorials online to learn.
The left stick's up/down controls throttle, and left/right controls yaw; the right stick's up/down controls pitch, and left/right controls roll.
These are the professional terms used for drones, which beginners may misunderstand, so in the new firmware they have been changed to plain language:
Left stick — Up: throttle up; Down: throttle down; Left: turn left; Right: turn right;
Right stick — Up: move forward; Down: move backward; Left: move left; Right: move right.
Flight mode description
Acro (FPV mode): manual throttle, which automatically returns to zero when the throttle is released; manual attitude control, with the attitude not self-leveling.
Angle (FPV mode): manual throttle, which automatically returns to zero when the throttle is released; manual attitude control, with the attitude self-leveling automatically.
Altitude Hold (similar to DJI flight mode; requires a sensor module, which is automatically recognized once installed): automatic throttle, where the throttle controls ascent/descent, and releasing the throttle automatically maintains the altitude; manual control of the horizontal direction.
Position Hold (similar to DJI flight mode; requires a sensor module, which is automatically recognized once installed): automatic throttle, where the throttle controls ascent/descent, and releasing the throttle holds a fixed altitude and hovers; the horizontal position is automatically maintained and can be manually adjusted, and releasing the stick holds a fixed position and hovers.
The drone drifts after takeoff.
Bilibili video "Analysis and Handling of Drift in the Chenguang E1 Quadcopter"
https://www.bilibili.com/video/BV1Jisd6pE64/
Flight distance/altitude
Theoretically, it can reach several hundred meters, but since there is no video transmission, it can only be flown within visual line of sight. In practice, once it is several tens of meters away, you can no longer clearly see where the aircraft is.
Why is the battery I received out of power?
The optimal storage state for the battery is at half charge, and the battery will self-discharge, so it is not fully charged when you receive it. Just charge it fully before use.
The kit includes a charging cable. A 5V/1A charging head is recommended. A standard battery will be fully charged in about 1 hour. During charging, the charging cable shows a red light, and the light turns off when fully charged.
The indicator light flashes / does not light up.
The LED next to the battery connector and the red indicator light on the development board are power indicator lights. They should stay on continuously after power-on. If they are off or flashing, there is a power supply problem—check the power supply circuit.
The blue indicator light on the development board is the status indicator by default. It flashes once after power-on: program self-test. Slow flashing: arming is normal. Fast flashing: alarm (low battery, remote control signal loss, etc.).
The indicator light on the back of the aircraft is the motor operation indicator, and its on/off state is consistent with the motor's power state: the indicator is on when the motor is powered, and off when the motor is unpowered. It does not light up before arming and lights up after arming.
The brightness of the motor indicator lights on the back of the aircraft is inconsistent / flickering: the brightness of the motor indicator lights varies with motor speed. After arming, the motor speed changes in real time under algorithm control, which is a normal phenomenon.
The MOSFET is burnt out.
Possible situations that may burn out the MOSFET:
- Motor wiring short circuit;
- Motor stall;
- Diode installed in reverse or with a cold solder joint;
Can't find the BIN firmware.
The firmware can be downloaded from the engineering documentation and the QQ group files.
PS: The source code is the pre-compilation source code of the firmware and cannot be directly flashed. There is no firmware in the source code.
PS: The firmware is developed by Chenguang Technology and is provided through Chenguang's official channels. Do not look for it in the Espressif flashing tool directory or on the flashing tool page.
Are U7, U8, U9, U10 / H3, H4 / H5, H6 empty (unpopulated)?
These are reserved interfaces and are empty (unpopulated).
U7, U8, U9, and U10 are reserved ESC (electronic speed controller) interfaces. If you want to convert to brushless motors, you can use these interfaces to connect ESCs.
H3 is a reserved receiver interface for the remote controller, and H4 is a spare reserved interface.
H5 and H6 are reserved interfaces for data transmission, and they are compatible with Chenguang expansion modules by default.
Download
Firmware
Propeller guard 3D model
Third-party tools and drivers
ESP32 flashing tool
ESP32 serial port driver
CH340 driver:
https://www.wch.cn/downloads/CH341SER_MAC_ZIP.html
Support
Monday-Friday (9:30-6:30) Saturday (9:30-5:30)
Email: services01@spotpear.com
[Tutorial Navigation]
- I. Project Overview
- Specifications
- Quick Start
- III. Project Replication
- IV. In-Depth Study
- Related Resources
- Reserved interfaces.
- Supports physical remote control, mobile app control, and the MAVLink protocol.
- Video transmission.
- V. Changelog
- FAQ
- Tips for connecting several polarized components.
- Component soldering positions.
- Unable to download/stuck at sync when flashing firmware
- The drone's Wi-Fi cannot be found / cannot be connected.
- The web remote control won't open.
- "IMU fault" is displayed.
- "Uncalibrated accelerometer" is prompted when unlocking.
- Normal range for IMU calibration data
- The ROLL item shows 170+ after IMU calibration.
- After IMU calibration, all data is NAN, or the PS command shows that the attitude data roll/pitch is all 0.000.
- The IMU gets stuck at the first step for a long time during calibration, and the remote control may even disconnect.
- Does the IMU need to be calibrated every time it is powered on?
- Will the motor spin if no operation is performed after power-on?
- After arming (at idle speed), some motors spin while others do not.
- The motor speeds are inconsistent when the throttle is increased.
- The drone rolls over or some motors stop spinning when taking off with throttle applied.
- How do I operate the web remote control?
- Flight mode description
- The drone drifts after takeoff.
- Flight distance/altitude
- Why is the battery I received out of power?
- The indicator light flashes / does not light up.
- The MOSFET is burnt out.
- Can't find the BIN firmware.
- Are U7, U8, U9, U10 / H3, H4 / H5, H6 empty (unpopulated)?
- Download
- Support